HAL and Bus Drivers
The bottom of the stack is deliberately thin. can-lite asks the hardware for exactly two things — send a frame, deliver a received frame — and everything above is written against those two and nothing else.
1. What the library requires of a bus

Four properties of that contract shape every layer above it:
| Property | Consequence |
|---|---|
| A payload is at most 8 bytes | Anything longer needs segmentation (Chapter 8), and payload composition is bounds-checked against the frame (Chapter 4) |
| Sending is asynchronous, completing through a callback | The core layer keeps its own queue and serialises sends (Chapter 4) |
| Exactly one receive callback exists per interface | The protocol object claims it at construction; a second consumer of the same bus is not supported |
| Identifier widths are distinguishable | can-lite uses extended identifiers exclusively and discards standard-identifier frames unseen, which is what lets it share a bus with other protocols (REQ-CAN-002) |
The library neither provides nor requires a particular implementation. On a microcontroller the platform HAL supplies one; the library takes a reference to it when the protocol object is constructed.
1.1 Controller errors on a target
hal::Can has no error path, but a CAN controller reports
bus off, error passive, error warning, lost and overflowed frames, and
the five frame-level error classes. MonitoredCan is a
hal::Can that adds one: the application installs a handler
for these errors, and every error is also counted per class in
CanBusErrorCounters, whose counters saturate rather than
wrap and file an unrecognised class under other.
MonitoredCanImpl wraps a platform driver and is what the
platform’s error interrupt reports into; the protocol object is
constructed over it like over any other hal::Can. Nothing
in the protocol layers reads these errors: what to do on bus off is the
application’s decision.
2. The host adapter
Host-side tooling needs more than the bus interface offers: opening an interface, reporting connection state, enumerating what the machine has, explaining what is missing, and integrating with a poll loop. The adapter interface adds exactly that — and nothing the protocol layer would ever call.

| Adapter | Platform | Interface names | Needs on the machine | Bitrates |
|---|---|---|---|---|
| SocketCAN | Linux | the network interface, can0 |
the CAN kernel modules | whatever the controller’s kernel driver can hit |
| slcan | Linux, Windows | the serial port, /dev/ttyACM0 or COM3 |
nothing beyond the operating system’s serial driver | the nine Lawicel rates, 10 kbit/s to 1 Mbit/s |
| candleLight | Windows | 1, 2, … in enumeration order |
WinUSB, which candleLight firmware binds automatically | any rate the controller’s clock divides exactly |
| PCAN-Basic | Windows | 1 to 16, the USB channel |
the PEAK-System driver package (PCANBasic.dll) |
the same nine rates as slcan |
| Kvaser CANlib | Windows | 0, 1, … |
the Kvaser CANlib driver (canlib32.dll) |
CANlib’s predefined rates: no 20 or 800 kbit/s |
| virtual bus | Linux, Windows | a bus name, default or any other |
a virtual CAN hub listening on the machine (§2.3) | the same nine rates as slcan |
Vendor libraries are loaded when an adapter connects or enumerates, never linked, and released through the vendor’s own unload call where it has one. Every adapter therefore builds without a vendor SDK, and a machine without the vendor driver gets an explanation instead of a failure to start. The pure parts — slcan line encoding and decoding, gs_usb host frames and the bit-timing search — live in a codec library with no platform dependency, so the host test suite covers them on every platform.
Each platform-specific adapter is guarded both in the build and in its header, so including the wrong one for a platform yields an empty translation unit rather than a compile error.
The observer interface exists for tooling — a bus monitor attaches to it and receives every frame in both directions, driver error text, and connection transitions. It is an observation channel, not a data path: the protocol still receives frames through the bus interface.
Extended identifiers only. Every adapter delivers and transmits 29-bit frames only; standard-identifier, remote and error frames stop at the driver, consistent with the protocol rule (REQ-CAN-002). A send with a standard identifier completes unsuccessfully.
Missing drivers. An adapter reports a plain-language reason for each driver it needs but cannot find — for example the kernel modules SocketCAN needs, or the vendor library PCAN-Basic loads. An adapter that needs nothing reports nothing.
Poll-loop integration. The adapter exposes a descriptor to select on and an entry point to call when it becomes readable, so a host application can service the bus from its own loop instead of dedicating a thread to it. On Linux the descriptor is a file descriptor. On Windows it is a waitable handle where the driver offers one — candleLight, and PCAN when its receive event could be installed — and −1 otherwise: Kvaser, and slcan, whose COM port offers no event. Calling the read entry point from a timer is always safe, because every adapter reads without blocking and bounds the work done per call. Adapters also defer their send completions through the event dispatcher rather than calling them from inside the send. That detail matters more than it looks: it guarantees the core layer’s queue is never re-entered from inside its own send (Chapter 10, §2).
Sending is bounded rather than free of waits. Two adapters on Windows wait inside the send: candleLight waits for each frame’s USB transfer to finish, up to its 100 ms pipe timeout, and the COM port under slcan writes synchronously, up to 50 ms. On Linux the only wait is a serial write that must finish a command the port took in part, up to 100 ms (§2.2). A host loop that services other work between frames should budget for these; making the Windows writes overlapped is a known, deliberate omission.
2.1 Several adapters behind one name
A tool that should work with whatever adapter is plugged in composes
the adapters behind the multi-adapter router. Each adapter is registered
with a prefix, optionally an alias, and at most one adapter is
registered without a prefix. Interface names take the form
prefix:channel; the router hands the channel to the adapter
that owns the prefix.

Only the adapter being connected is active. Its frames, errors and connection changes reach the router’s observer and receiver; the others stay silent. When the active adapter reports that its connection was lost, the router forgets it. Interfaces are enumerated with their prefix, so the names a tool offers are the names it can connect to.
Missing drivers are reported only when no registered adapter is usable — usable meaning its drivers are present and it has at least one interface. Then every adapter’s reasons are reported together, which is what a user needs to see when nothing works; while one adapter works, a missing vendor driver for another is not worth mentioning.
The platform composition registers the set for the build platform:
| Platform | Registered adapters |
|---|---|
| Linux | SocketCAN without a prefix, slcan as slcan: with the
alias CANable:, virtual: |
| Windows | PCAN:, Kvaser:, slcan as
slcan: with the alias CANable:,
candleLight:, virtual: |
2.2 SocketCAN, slcan and candleLight specifics
SocketCAN checks the interface before touching it, then sets the
bitrate over the kernel’s routing netlink, the interface
ip link itself uses: the link is taken down, given the new
bit timing and brought back up. It does this only for a CAN controller
that is not already up at that bitrate, so a virtual CAN interface,
which has no bit timing, is left alone, and so is an interface an
administrator configured beforehand. Changing the bitrate needs root or
CAP_NET_ADMIN; a refusal is reported and the connection
refused, rather than the bus opening at a rate nobody asked for. Each
read call drains up to 256 frames; remote and error frames are
dropped.
slcan opens a channel with three commands: close, select the bitrate,
open. Connecting writes them and returns; the adapter reports itself
connected once the device has acknowledged the bitrate and the open
command, or once 250 ms have passed without a rejection. The second path
is the usual one: the CANable and CANtact firmware, and the firmware
derived from them, never acknowledge a command, so silence cannot be
read as failure and a device that answers nothing is still an slcan
device. A device that is already closed rejects the first command, so
the answer to that close is ignored. A rejection of either of the others
closes the port, says why and reports the connection lost. The window is
timed, which is why the slcan adapter needs the timer service, as the
protocol objects do. Acknowledgements that arrive after the window are
ignored, and rejections after the channel is open are reported as
errors. When the serial port cannot be opened the reason is named — not
found, in use, or access denied (on Linux the user must be in the
dialout group). A write the port cannot take in one piece
is finished within 100 ms or fails, so a command is never left
half-written on the line.
candleLight adapters describe their CAN controller’s timing limits. The adapter searches those limits for timing that divides the controller clock exactly into the requested bitrate with the sample point closest to 87.5 %, and refuses a bitrate it cannot hit exactly.
2.3 The virtual CAN hub
Host tools sometimes need a bus with no hardware on it: a simulated node to talk to, or several programs on one machine that should see each other’s frames. The virtual CAN hub is that bus. It runs inside a host program, listens on the loopback interface only (port 29536 unless the program chooses another), and carries any number of named buses at once; a frame never leaves the machine.
A program reaches a bus as virtual:<bus name>. The
virtual adapter is the slcan adapter over a port that is a loopback
connection to the hub instead of a serial device, so the hub speaks
slcan: it is the device. Opening the port connects to the hub and names
the bus with one line of its own, an @ followed by the
name; then the adapter’s usual close, bitrate and open commands follow,
and the hub answers each as a device would. The join line is not
answered when it succeeds, so the adapter’s handshake counts the three
replies it always counts. A hub that is not running makes the port fail
to open, which the adapter reports as a port not found; enumeration
lists default while a hub is listening, and any other name
can be typed.
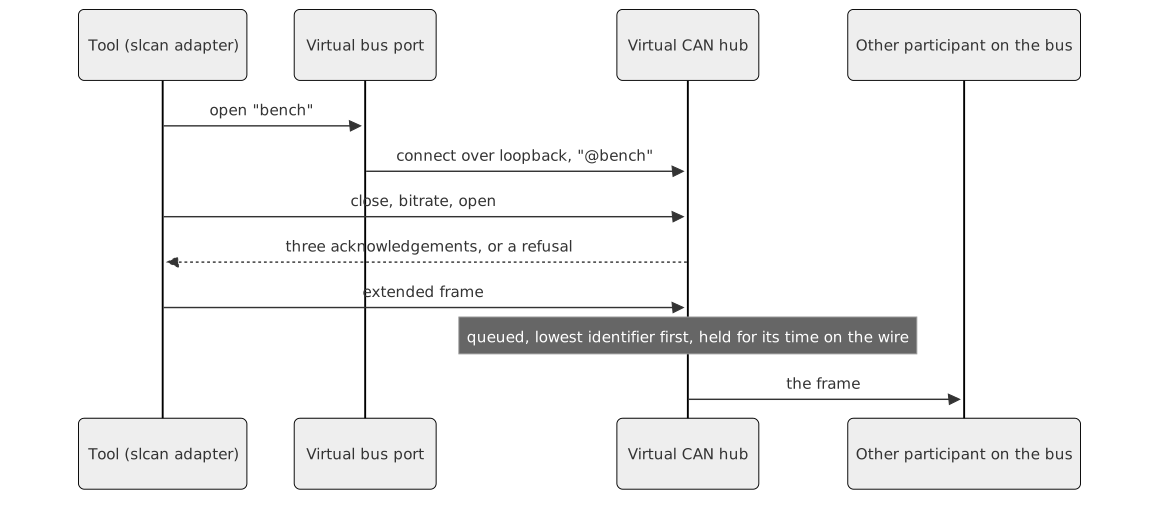
The hub keeps what a real bus imposes:
- One bitrate per bus. The first participant to open a bus sets its bitrate; a participant asking for another while the bus has open members is refused at the bitrate command, as a controller at the wrong rate would never join the bus. The adapter reports that refusal and closes.
- Arbitration. Frames waiting for the bus go out lowest identifier first.
- Time on the wire. Each frame holds the bus for its length at the bus’s bitrate, counting worst-case bit stuffing, so a bus loaded with streams runs at the rate a real one would; a frame reaches the other open participants when its transmission ends, never the sender itself.
- Only open channels listen. A participant that has joined but not opened, or has closed, receives nothing; a frame sent before opening is refused.
What it does not model: error frames, bus-off, acknowledgement slots and retransmission. A participant whose queue overflows (64 frames waiting) has the frame refused rather than retried. The hub serves sixteen participants across four buses. Leaving the bus takes a participant’s waiting frames with it; when the hub stops, every adapter on it reports its connection lost.
The pure part — the bus model with its arbitration and timing — has no socket in it and is covered by the host test suite on every platform; the hub around it and the virtual bus port are the only code touching the loopback socket.
3. The virtual bus used by the integration tests
The integration tests replace hardware with a pair of connected virtual buses: one instance’s send lands in the other’s receive callback, which models the two-node topology the tests use. A second entry point pushes a frame straight into the receive callback, bypassing the peer — that is how a test produces something no correct peer would ever send: a malformed acknowledgement, a wrong sequence number, an unknown category, a standard-identifier frame. Disconnecting models bus loss, which is how the liveness timeouts of Chapters 6 and 7 are exercised.
What the virtual bus does not model is the boundary of what the integration tests can prove:
| Not modelled | Consequence for testing |
|---|---|
| Arbitration and priority | Frame order is send order, so priority effects are reasoned about (Chapter 11), not observed |
| Bus errors, error frames, bus-off | Sending always succeeds; failure paths are exercised through mocks instead |
| Transmission delay and bit timing | Bus-load budgeting is arithmetic, not measurement |
| More than two endpoints | Multi-server behaviour is covered at the unit level |
4. What can-lite assumes of a driver
A driver that satisfies the interface but breaks any of these produces protocol-level misbehaviour rather than an obvious failure, so they are worth stating:
- Each send completes exactly once, and not from inside the send call itself. The core layer dequeues the next frame from within that completion; a synchronous completion turns queue drain into recursion.
- Whole frames are delivered, with the identifier already separated from the payload.
- The receive callback runs in the application’s own context. A driver that calls it from an interrupt must marshal through the event dispatcher first.
- Frames arrive in the order they were received. Sequence validation rejects reordered commands, so a reordering driver produces spurious sequence errors.
- Acceptance filtering, if configured, must admit the broadcast address. The client’s heartbeat is broadcast; a filter that matches only the node’s own address will make the server report its client offline on an idle bus.
Point 5 is the one that bites during MCU integration, and it is catalogued in Chapter 10, §6.